Detection2DArray
The detections of one frame; header is the image's header.
Preview
The figure robot_msgs.viz.plot(example) draws for the example below.
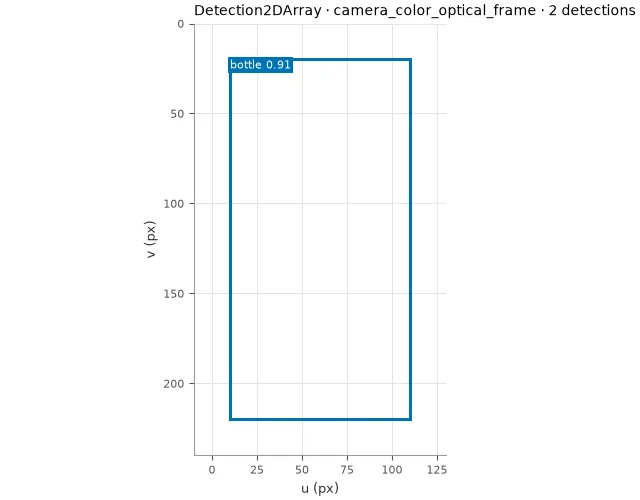
Fields
| Name | Type | Default |
|---|---|---|
header | Header | Header() |
detections | tuple[Detection2D, ...] | () |
Example
One instance from the package's own test catalog; the output is its real repr().
Detection2DArray(header=Header(stamp=1761600000.25, frame_id='camera_color_optical_frame'), detections=(Detection2D(header=Header(stamp=1761600000.25, frame_id='camera_color_optical_frame'), results=(ObjectHypothesisWithPose(hypothesis=ObjectHypothesis(class_id='bottle', score=0.91), pose=Pose(position=Point(x=0.4, y=-0.1, z=0.25), orientation=Quaternion(x=-0.10566871683993562, y=0.6991667342497077, z=0.10566871683993563, w=0.6991667342497078))),), bbox=BoundingBox2D(center=Pose2D(x=60.0, y=120.0, theta=0.0), size_x=100.0, size_y=200.0), id='7'), Detection2D(header=Header(stamp=1761600000.25, frame_id='camera_color_optical_frame'), results=(ObjectHypothesisWithPose(hypothesis=ObjectHypothesis(class_id='bottle', score=0.91), pose=Pose(position=Point(x=0.4, y=-0.1, z=0.25), orientation=Quaternion(x=-0.10566871683993562, y=0.6991667342497077, z=0.10566871683993563, w=0.6991667342497078))),), bbox=BoundingBox2D(center=Pose2D(x=60.0, y=120.0, theta=0.0), size_x=100.0, size_y=200.0), id='8')))to_dict() as JSON
{
  "_type": "vision/Detection2DArray",
  "header": {
    "_type": "std/Header",
    "stamp": 1761600000.25,
    "frame_id": "camera_color_optical_frame",
    "meta": {}
  },
  "detections": [
    {
      "_type": "vision/Detection2D",
      "header": {
        "_type": "std/Header",
        "stamp": 1761600000.25,
        "frame_id": "camera_color_optical_frame",
        "meta": {}
      },
      "results": [
        {
          "_type": "vision/ObjectHypothesisWithPose",
          "hypothesis": {
            "_type": "vision/ObjectHypothesis",
            "class_id": "bottle",
            "score": 0.91
          },
          "pose": {
            "_type": "geometry/Pose",
            "position": {
              "_type": "geometry/Point",
              "x": 0.4,
              "y": -0.1,
              "z": 0.25
            },
            "orientation": {
              "_type": "geometry/Quaternion",
              "x": -0.10566871683993562,
              "y": 0.6991667342497077,
              "z": 0.10566871683993563,
              "w": 0.6991667342497078
            }
          },
          "covariance": null
        }
      ],
      "bbox": {
        "_type": "vision/BoundingBox2D",
        "center": {
          "_type": "geometry/Pose2D",
          "x": 60.0,
          "y": 120.0,
          "theta": 0.0
        },
        "size_x": 100.0,
        "size_y": 200.0
      },
      "id": "7"
    },
    {
      "_type": "vision/Detection2D",
      "header": {
        "_type": "std/Header",
        "stamp": 1761600000.25,
        "frame_id": "camera_color_optical_frame",
        "meta": {}
      },
      "results": [
        {
          "_type": "vision/ObjectHypothesisWithPose",
          "hypothesis": {
            "_type": "vision/ObjectHypothesis",
            "class_id": "bottle",
            "score": 0.91
          },
          "pose": {
            "_type": "geometry/Pose",
            "position": {
              "_type": "geometry/Point",
              "x": 0.4,
              "y": -0.1,
              "z": 0.25
            },
            "orientation": {
              "_type": "geometry/Quaternion",
              "x": -0.10566871683993562,
              "y": 0.6991667342497077,
              "z": 0.10566871683993563,
              "w": 0.6991667342497078
            }
          },
          "covariance": null
        }
      ],
      "bbox": {
        "_type": "vision/BoundingBox2D",
        "center": {
          "_type": "geometry/Pose2D",
          "x": 60.0,
          "y": 120.0,
          "theta": 0.0
        },
        "size_x": 100.0,
        "size_y": 200.0
      },
      "id": "8"
    }
  ]
}
Long arrays are cut after 16 values and say so with “…”.
Functions
Constructors
Classmethods and staticmethods: ways to build one.
Methods
Return new values; messages are never mutated.
as_arrays() -> dict[str, Array]The batch view: boxes_xyxy (N, 4), scores (N,), class_ids (N,) strings.
filtered(
    min_score: float | None = None,
    class_ids: Iterable[str] | None = None,
) -> Detection2DArray
Detections whose best score is at least min_score and whose class is in class_ids.
nms(iou_threshold: float) -> Detection2DArrayNon-maximum suppression, class-agnostic: highest scores win, overlaps above
to_dict
from Msgto_dict() -> dict[str, Any]JSON-safe dict with a "_type" key; arrays keep their dtype and shape.
Operators
Python operators and protocols the type supports.